Skip to content
Colin WolffSYS_DOMAIN: colinwolff.dev // NO_SOCIALS
SYS_STATUS: ONLINE

[SEC-02 // SYSTEM LOGS]

Systems & Engineering Logs

A chronological stream of specifications, essays and field notes. Newest first, deduplicated by identifier, never retro-edited.

ENTRIES: 07 // NEWEST FIRST

[NOTE]

Logs Hub Now Live

Projects, essays and short updates now share one chronological stream at /logs, newest first.

[LOG-02]

Zero Runtime JavaScript Is a Budget, Not a Badge

[POST]SEP 14, 2026

Treating hydration as a line item you must justify, and the three interactions on this site that actually earned their kilobytes.

  • performance
  • astro
  • architecture
[LOG-01]

Hairlines Over Shadows

[POST]AUG 27, 2026

Why this interface is built from one-pixel rules and tonal shifts instead of elevation, and how that decision simplifies the CSS system.

  • design-systems
  • tailwind
  • css
[SYS-03]

Solar Field Logger with Lossless Compression

[PROJECT]STATUS: BENCH TEST

Remote environmental data logger that survives six months unattended on a 5 W panel and stores 12 channels of calibrated sensor data in a compact binary log.

// Power
5 W panel · 2×18650 · MPPT charge controller
// Core
STM32L4 in stop mode · 32.768 kHz RTC wake
// Sensors
I²C temperature, RH, soil moisture, UV index
// Storage
8 MB NOR flash · append-only framed log
// Duty cycle
210 ms awake per 60 s sample window
// Runtime
187 days without sun (measured, no blackout)
// Log density
31 bytes/sample after delta encoding
[SYS-02]

Closed-Loop Tabletop CNC Control Interface

[PROJECT]STATUS: WIP

G-code motion planner with optical encoder feedback, dynamic feed-rate correction and a deterministic step pipeline for desktop parametric machining.
// Controller
ESP32-S3 dual-core · FreeRTOS tasks pinned per core
// Planner
Look-ahead trapezoidal velocity profile · 128-block buffer
// Feedback
1000 CPR optical quadrature on all three axes
// Spindle
1.5 kW BLDC · isolated PWM + tachometer input
// Repeatability
±0.025 mm across 300 mm envelope
// Step jitter
1.4 µs σ at 40 kHz step rate
// Recovery
Mid-program resume within one block
[SYS-01]

Modular Automotive CAN-Bus Head Unit

[PROJECT]STATUS: NOMINAL
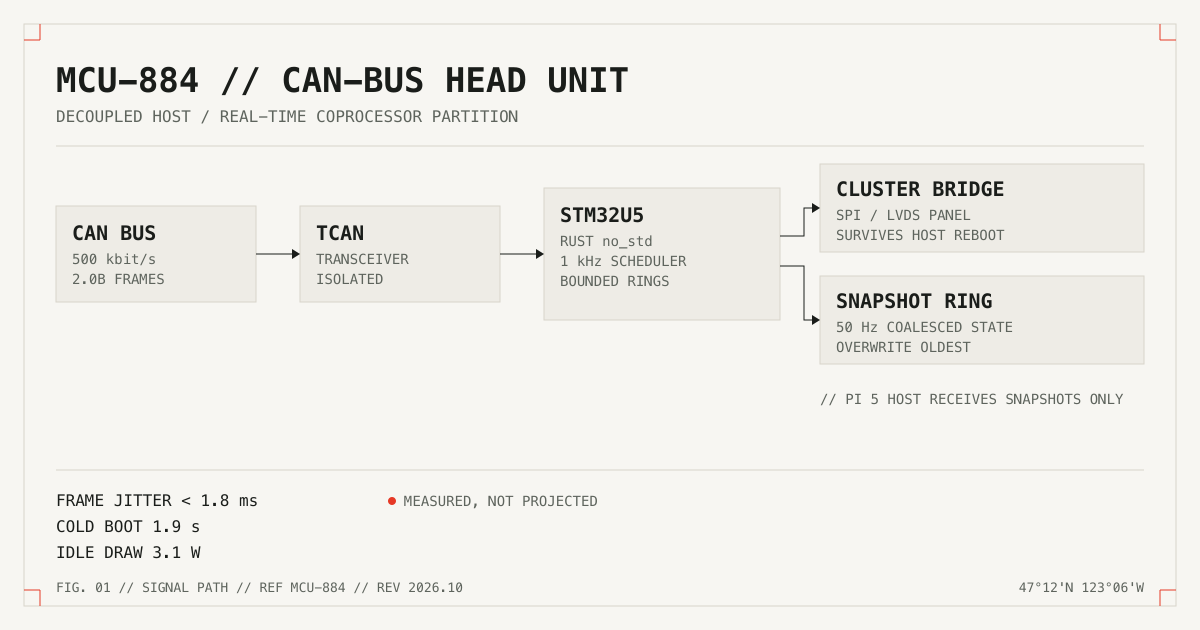
Signal path from the vehicle CAN bus through the transceiver and STM32U5 coprocessor to the cluster bridge and host snapshot ring.

Double-DIN instrument console that merges real-time CAN telemetry with decoupled host media processing, without touching the factory wiring harness.

// Compute
Raspberry Pi 5 host · STM32U5 real-time coprocessor
// Firmware
Rust no_std on Cortex-M33 · A/B OTA with rollback
// Bus
CAN 2.0B via TCAN transceivers · 500 kbit/s
// Display
1920×720 LVDS panel · SPI instrument cluster bridge
// Frame jitter
< 1.8 ms worst case over 10M frames
// Cold boot
1.9 s to first rendered frame
// Idle draw
3.1 W (host suspended, cluster live)