[SYS-01]
Modular Automotive CAN-Bus Head Unit
[PROJECT]STATUS: NOMINALREF: MCU-884REV: 2026.10
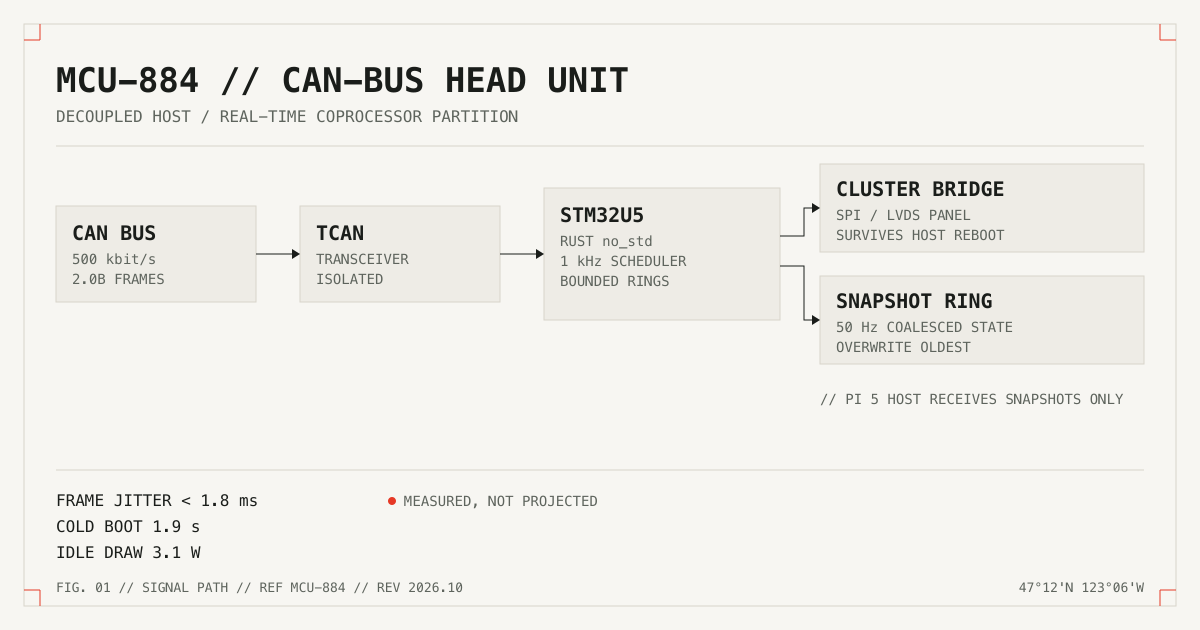
Double-DIN instrument console that merges real-time CAN telemetry with decoupled host media processing, without touching the factory wiring harness.
- // Compute
- Raspberry Pi 5 host · STM32U5 real-time coprocessor
- // Firmware
- Rust no_std on Cortex-M33 · A/B OTA with rollback
- // Bus
- CAN 2.0B via TCAN transceivers · 500 kbit/s
- // Display
- 1920×720 LVDS panel · SPI instrument cluster bridge
- // Frame jitter
- < 1.8 ms worst case over 10M frames
- // Cold boot
- 1.9 s to first rendered frame
- // Idle draw
- 3.1 W (host suspended, cluster live)